ICRA 2026
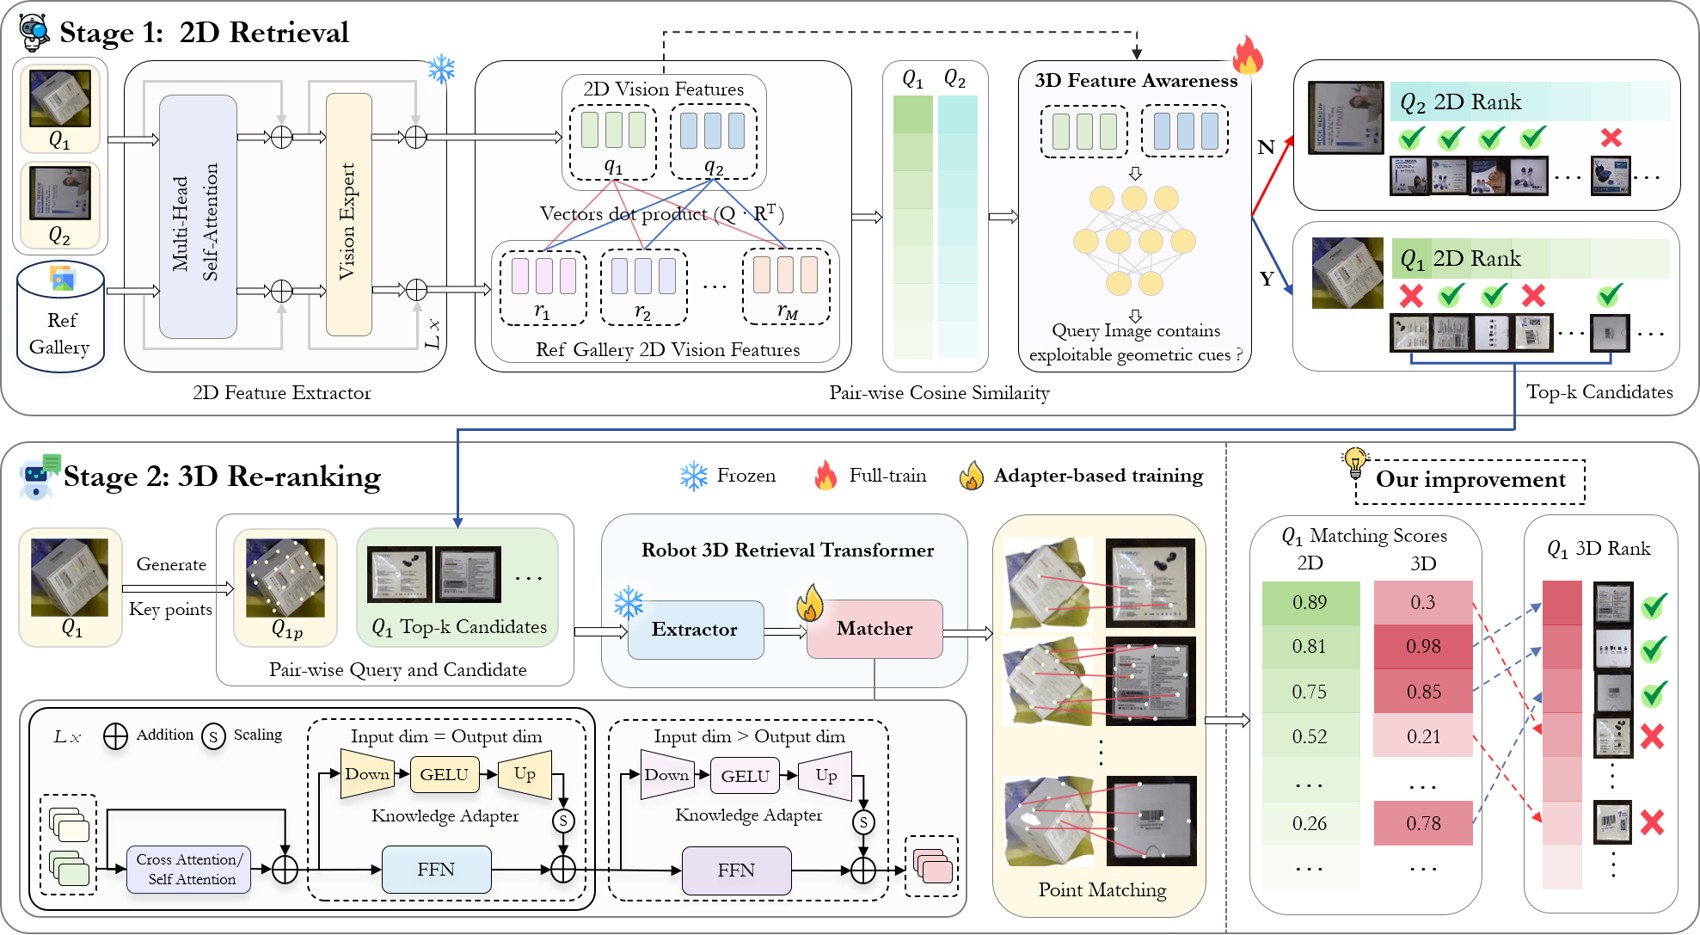
Identifying what a robot picks up
RoboEye first ranks objects by their appearance in 2D. When similar candidates are hard to tell apart, it checks whether their 3D keypoints match.
Selected projects in computer vision and multimodal learning.
ICRA 2026
RoboEye first ranks objects by their appearance in 2D. When similar candidates are hard to tell apart, it checks whether their 3D keypoints match.
ICML 2026
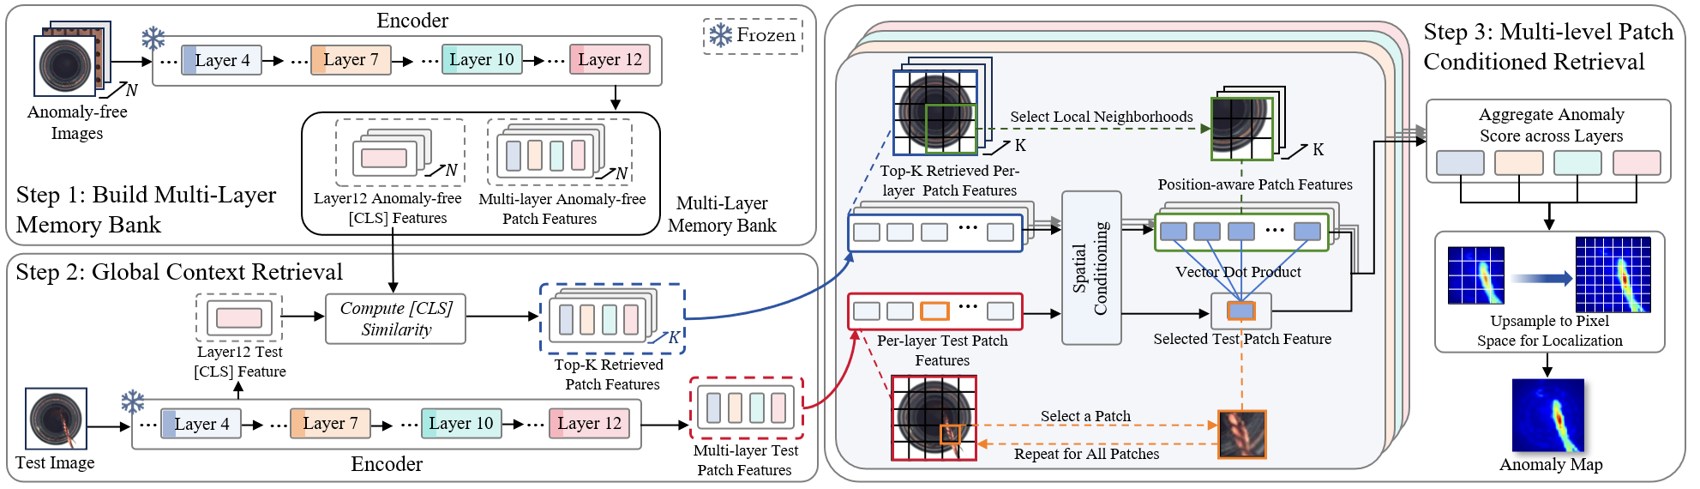
RAD compares local features of a test image with those of defect-free examples. Regions without a close match are flagged for inspection.
SIGIR 2026
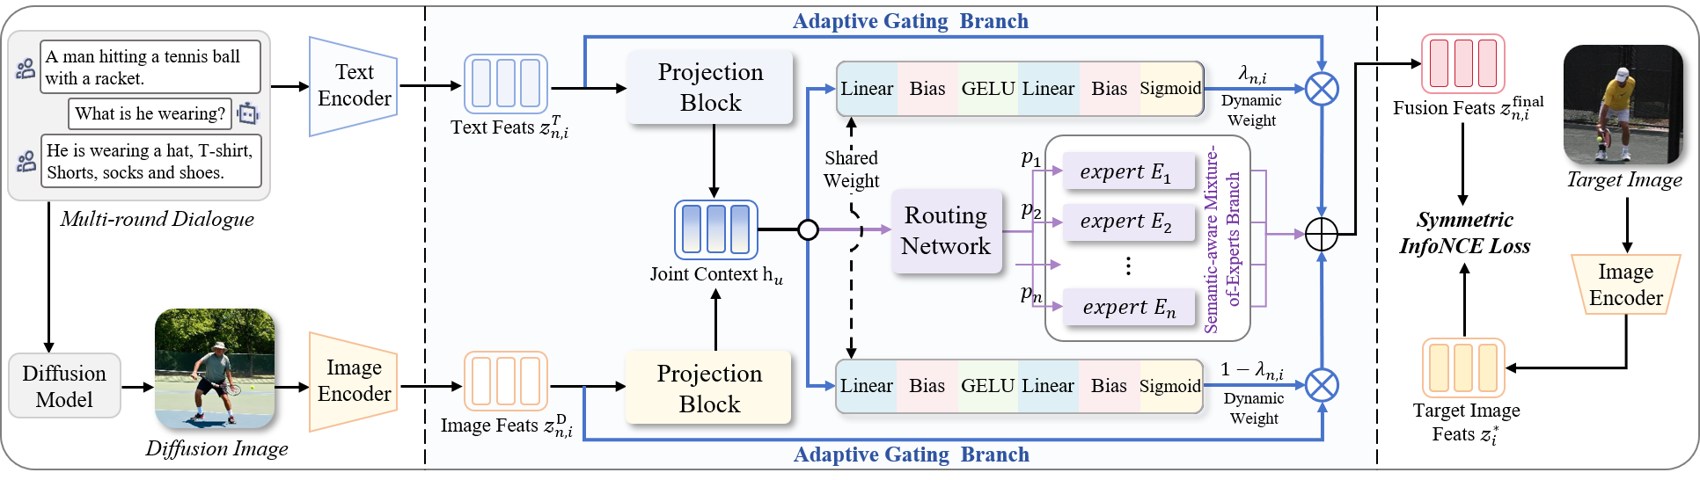
A generated image can capture a searcher’s intent or introduce distracting details. ADaFuSE learns how much weight to give each image and text cue.
TIM · 2026
ICML · 2026
SIGIR · 2026
ICRA · 2026
TIE · 2026
SIGIR · 2025
ECCV · 2024